DATA FIRST. MODELS NEXT.
DATA
Proprietary POV hardware captures human experience at industrial scale. Curated streams for manipulation, interaction and long-horizon learning.
- DATA PRODUCTS
- 3
- FRONTIER RESEARCH
- 3
- 30 FPS
- 1080p
DATA PRODUCTS
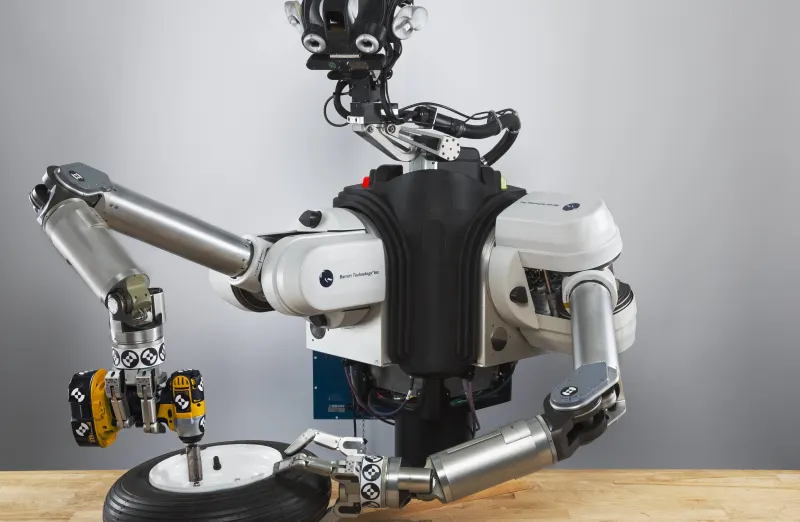 DS_001
HAND-OBJECT INTERACTION
MANIPULATION TASKS
High-density POV clips of real human manipulation: cooking, cleaning, picking, placing, tool use, and more.
- dense trajectories
- action-rich
- 1080p/30fps
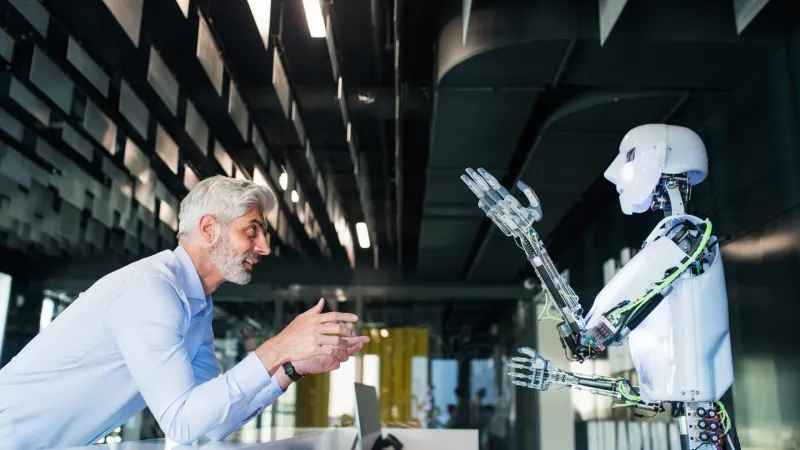 DS_002
PERCEPTION & AFFORDANCE
HUMAN-ENV INTERACTION
POV videos with object cues, spatial context, and natural scene dynamics from real home/work environments.
- affordances
- context-rich
- indoor workflows
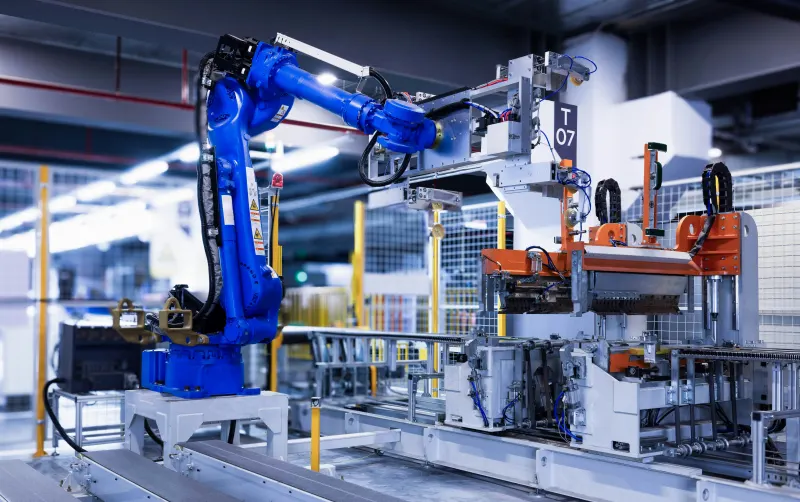 DS_003
MULTI-STEP SEQUENCES
LONG-HORIZON EPISODES
Extended POV episodes with multi-step actions, environment changes, mistakes, and recoveries.
- complex planning
- error-recovery
- temporal-reasoning
FRONTIER RESEARCH
- 01
POV-LEARN
IMITATION LEARNING
First-person video data pipelines for scalable imitation learning. Enabling robots to learn from human demonstrations.
- 02
ACTION-VLA
VLA MODELS
Vision-Language-Action model integration research. Building bridges between perception and robotic control.
- 03
DEXTEROUS-X
ROBOTIC MANIPULATION
Advanced manipulation priors from egocentric video datasets. Teaching robots fine-grained motor skills.
DATA CATALOGUE
Browse samples, schemas and licensing for every dataset. Sign in with an institutional account to request access.